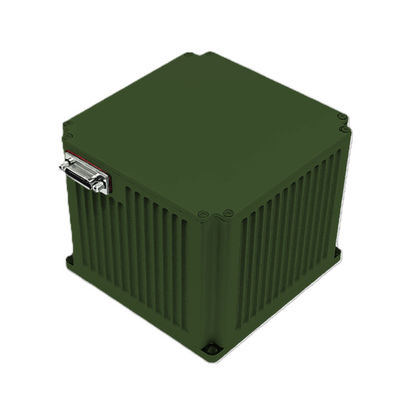
A vehicle-mounted FOG orientation and positioning system (gyro bias repeatability ≤50μg) with fast startup, RS-422/Ethernet output and extended-temperature operation, suited to demanding navigation and stabilization applications.
The Merak-L03(60S) FOG Orientation and Positioning System (INS-L) is a fiber optic gyroscope (FOG) orientation and positioning system (INS-L) from the Merak series, designed for vehicle-mounted north-finding, orientation and positioning. It combines a fiber optic gyroscope triad with quartz flexible accelerometers and supports both static and moving-base alignment. The unit delivers a dynamic range of at least ±400°/s with excellent bias stability and low angular random walk. Key performance figures include Accelerometer Bias Repeatability (monthly, 1σ) ≤50μg; Accelerometer Scale Factor Accuracy (monthly, 1σ) ≤50ppm; Gyro Bias Repeatability (1σ) ≤0.05°/hr; Gyro Scale Factor Accuracy (1σ) ≤50ppm; Gyro Accuracy (10 s, 1σ) ≤0.1°/hr; Angular Random Walk (1σ) ≤0.01°/√hr. A companion “Deep Pilot” variant (SD-GL03) with the same specifications is also available. Electrical interfacing is provided through high-speed serial or Ethernet links with fast startup, and the unit operates over an extended industrial temperature range with high MTBF for long-endurance missions. Typical applications include ground vehicles, tanks, self-propelled artillery and other vehicle-mounted platforms that require rapid orientation, heading keeping and positioning, optionally aided by GNSS or an odometer. All specifications below are taken directly from the manufacturer’s 2026 catalog and datasheet.
Key specifications: Accelerometer Bias Repeatability (monthly, 1σ): ≤50μg; Accelerometer Scale Factor Accuracy (monthly, 1σ): ≤50ppm; Gyro Bias Repeatability (1σ): ≤0.05°/hr; Gyro Scale Factor Accuracy (1σ): ≤50ppm; Gyro Accuracy (10 s, 1σ): ≤0.1°/hr; Angular Random Walk (1σ): ≤0.01°/√hr.
Specifications
| Parameter | Value | Unit |
|---|---|---|
| Accelerometer Bias Repeatability (monthly, 1σ) | ≤50μg | |
| Accelerometer Scale Factor Accuracy (monthly, 1σ) | ≤50ppm | |
| Gyro Bias Repeatability (1σ) | ≤0.05°/hr | |
| Gyro Scale Factor Accuracy (1σ) | ≤50ppm | |
| Gyro Accuracy (10 s, 1σ) | ≤0.1°/hr | |
| Angular Random Walk (1σ) | ≤0.01°/√hr | |
| Angular Rate Range | ≥±400°/sec | |
| Angular Acceleration | 100000°/s² | |
| Acceleration Range | ≥40g | |
| Attitude | Any Orientation | |
| Input/Output Interface | 3 RS422 full-duplex serial ports, 1 100M Ethernet port | |
| Alignment Time | ≤5min | |
| Position Error (10 min zero-speed correction / 2 h) | ≤60m,CEP | |
| Position Accuracy (INS/Odometer-aided) | ≤2.0%D,RMS | |
| Position Accuracy (INS/GNSS-aided) | better than satellite accuracy | |
| North-Finding / Orientation Accuracy | ≤10.0mil,RMS | |
| Heading Keeping Accuracy (2 h) | ≤5.0mil,RMS | |
| Heading Accuracy (INS/GNSS-aided) | ≤5.0mil,RMS | |
| Pitch & Roll Accuracy | ≤2.0mil,RMS | |
| Power Consumption | ≤15W | |
| Dimensions (L×W×H, mm) | 110×110×100 | |
| Weight | ≤1.7kg | |
| Operating Temperature | -40°C~60°C | |
| Shock | 15g, Half-sine wave 11ms | |
| Input Voltage | DC24V(±25%) | |
| Cooling | Conduction to mounting plate | |
| Vibration | 20~2000Hz,6.06g | |
| MTBF | ≥20000 hours |
All specifications are taken from the manufacturer’s current datasheet.
Reviews
There are no reviews yet.