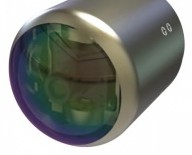
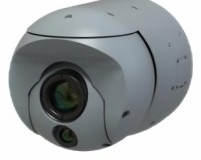
The SV-2-70VL Visible Light Platform Image Seeker identifies and tracks targets by their optical signature and outputs the deviation angle from the optical axis to guide the carrier precisely onto the target. Built around a 2560×1920 CMOS sensor with a 25 mm lens (12.8° × 9.6° FOV), the seeker performs AI autonomous recognition of vehicles, specific targets and UAVs, tracking to 2-pixel accuracy. System latency is 80 ms with line-of-sight angles output at 50 Hz and angular error of 0.3° or better within the ±10° field. The two-axis stabilized platform covers ±30° in pitch and yaw with isolation of 2% or better, tracks at angular rates up to 25°/s, and supports rotation speeds of 50°/s or more, keeping the target centered through aggressive maneuvers of high-speed UAVs and high-speed missiles. The compact Φ70 × 90 mm, ≤320 g package withstands 300 g longitudinal overload, draws ≤20 W from an 18–32 V supply, and offers RS422/RS232 plus 100M Ethernet interfaces for −40 °C to +60 °C operation.
Specifications
| Parameter | Value | Unit |
|---|---|---|
| Weight | ≤320 | g |
| Dimensions | Φ70×90 | mm |
| Overload resistance | Longitudinal 300, Lateral 50 | g |
| Visible camera type | CMOS | – |
| Visible resolution | 2560×1920 | pixels |
| Visible FOV | 12.8×9.6 (25 mm lens) | ° |
| Tracking accuracy | 2 | pixels |
| Image compression | H.265 | – |
| Line-of-sight angle output | 50 | Hz |
| System latency | 80 | ms |
| Autonomous recognition types | Vehicles, specific targets, UAVs | – |
| Line-of-sight angle error | ≤0.3 (±10° field of view) | ° |
| Maximum rotation speed | ≥50 | °/s |
| Frame range | Pitch −30 to +30; Yaw −30 to +30 | ° |
| Isolation | ≤2 (3 Hz/1°) | % |
| Max tracking angular velocity | −25 to +25 | °/s |
| Maximum misalignment angle | ≤0.3 | ° |
| Communication interface | RS422/RS232, 100M Ethernet | – |
| Power supply | 18–32 V, average ≤20 | W |
| Working temperature | −40 to +60 | °C |
Reviews
There are no reviews yet.